tsai-civ2
Civilization II in a browser, full-game harness, live action probabilities.
Playgrounds and demosBenchmarks and evals
Home / Games, robotics and simulation
19 entries
Civilization II in a browser, full-game harness, live action probabilities.
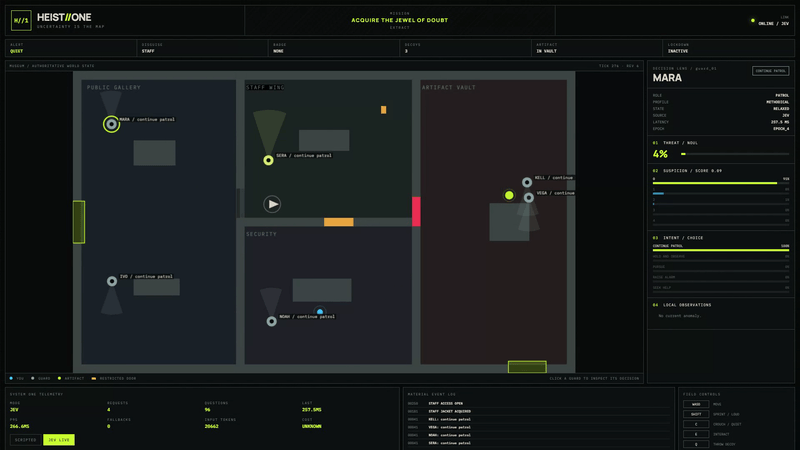
Stealth game where Jev makes the guards' judgments and deterministic code owns the world.
One Choice per tick; legal moves and facts generated in code.
Generation 3 Pokémon through Showdown and a real FireRed ROM.
Zero-shot English goals on a simulated Franka arm; Jev chains hardcoded primitives.
Snake controlled by parallel Jev assessments, one API call per tick.
Three.js driving simulator where Jev picks steering and speed from sampled paths up to four times a second; [drive it](https://jevpilot.standardagents.ai).
Top-down car in the browser sending four typed questions every 200 ms, with confidence-gated overrides in code.
Plays Clash Royale with Jev choosing cards and placements from Qwen battlefield vision and local OpenCV hand and elixir recognition.
Browser workbench for embodied experiments in MuJoCo where every robot step is a visible Jev decision, backed by a local model or a cloud API.
Plays Super Mario Bros. from structured emulator state; Jev picks the NES controller input directly.
Plays the original StarCraft shareware through keyboard and mouse, action probabilities recorded.
Browser-native Doom agent with structured spatial state and live decision telemetry.
Pokemon Red on PyBoy: code owns the route and the arithmetic, Jev picks only at branches, and every battle turn logs a faint prediction scored by Brier against what the RAM says.
Kills the dragon on a vanilla server with a frontier model planning and Jev selecting every player action; the logged run took 131 Jev decisions and 35 planner calls.
Camera-only drone in MuJoCo with Jev in the loop at 2.5 Hz.
Connect Four with nine swappable query strategies for the same model, every answer graded against engine ground truth in a live inspector, and a match runner that plays 100 games a minute: representation changes alone moved the win rate 52 points.
Command line for LLM-piloted robots across seven bodies, with an optional Jev stepper that picks among calls without ever writing a joint angle.